Stair-Climbing Robot
COMPLETE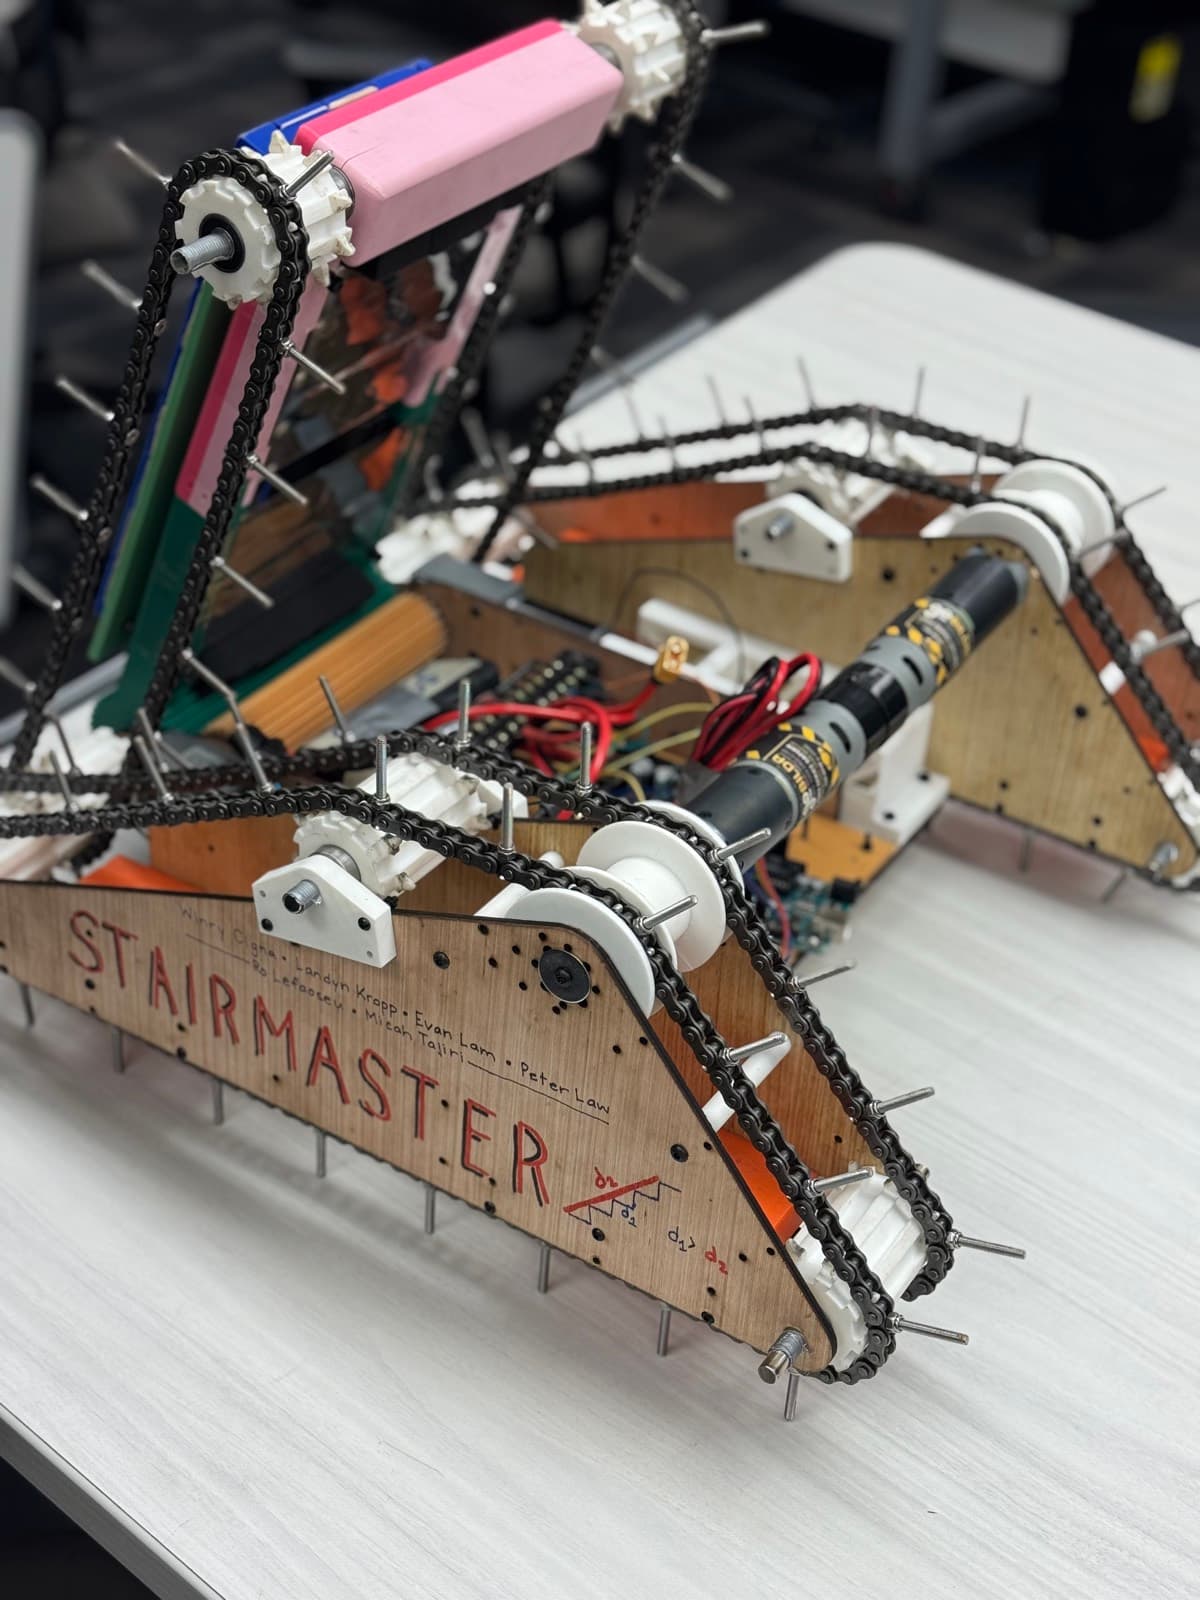
Overview
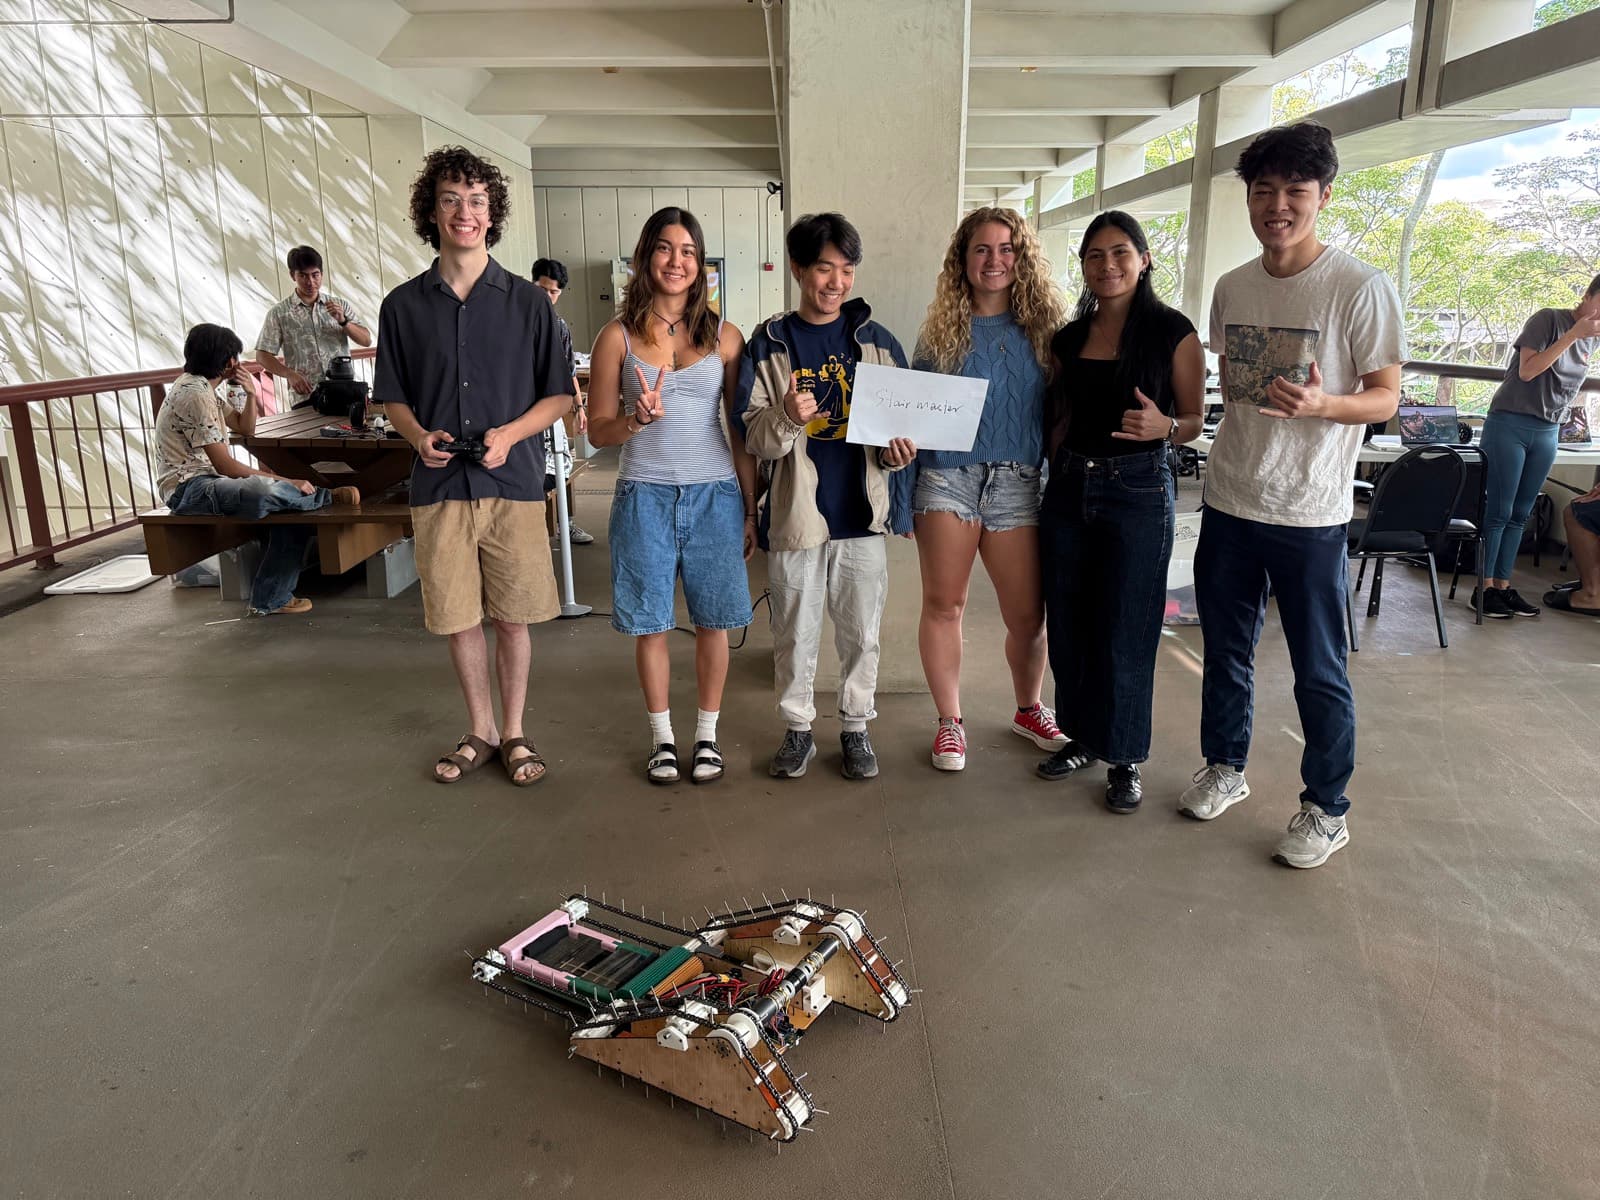
Our six-person team designed and fabricated a stair-climbing robot for ME213 at UH Mānoa. It placed 1st in my Fall 2025 ME213 section.
My Contributions
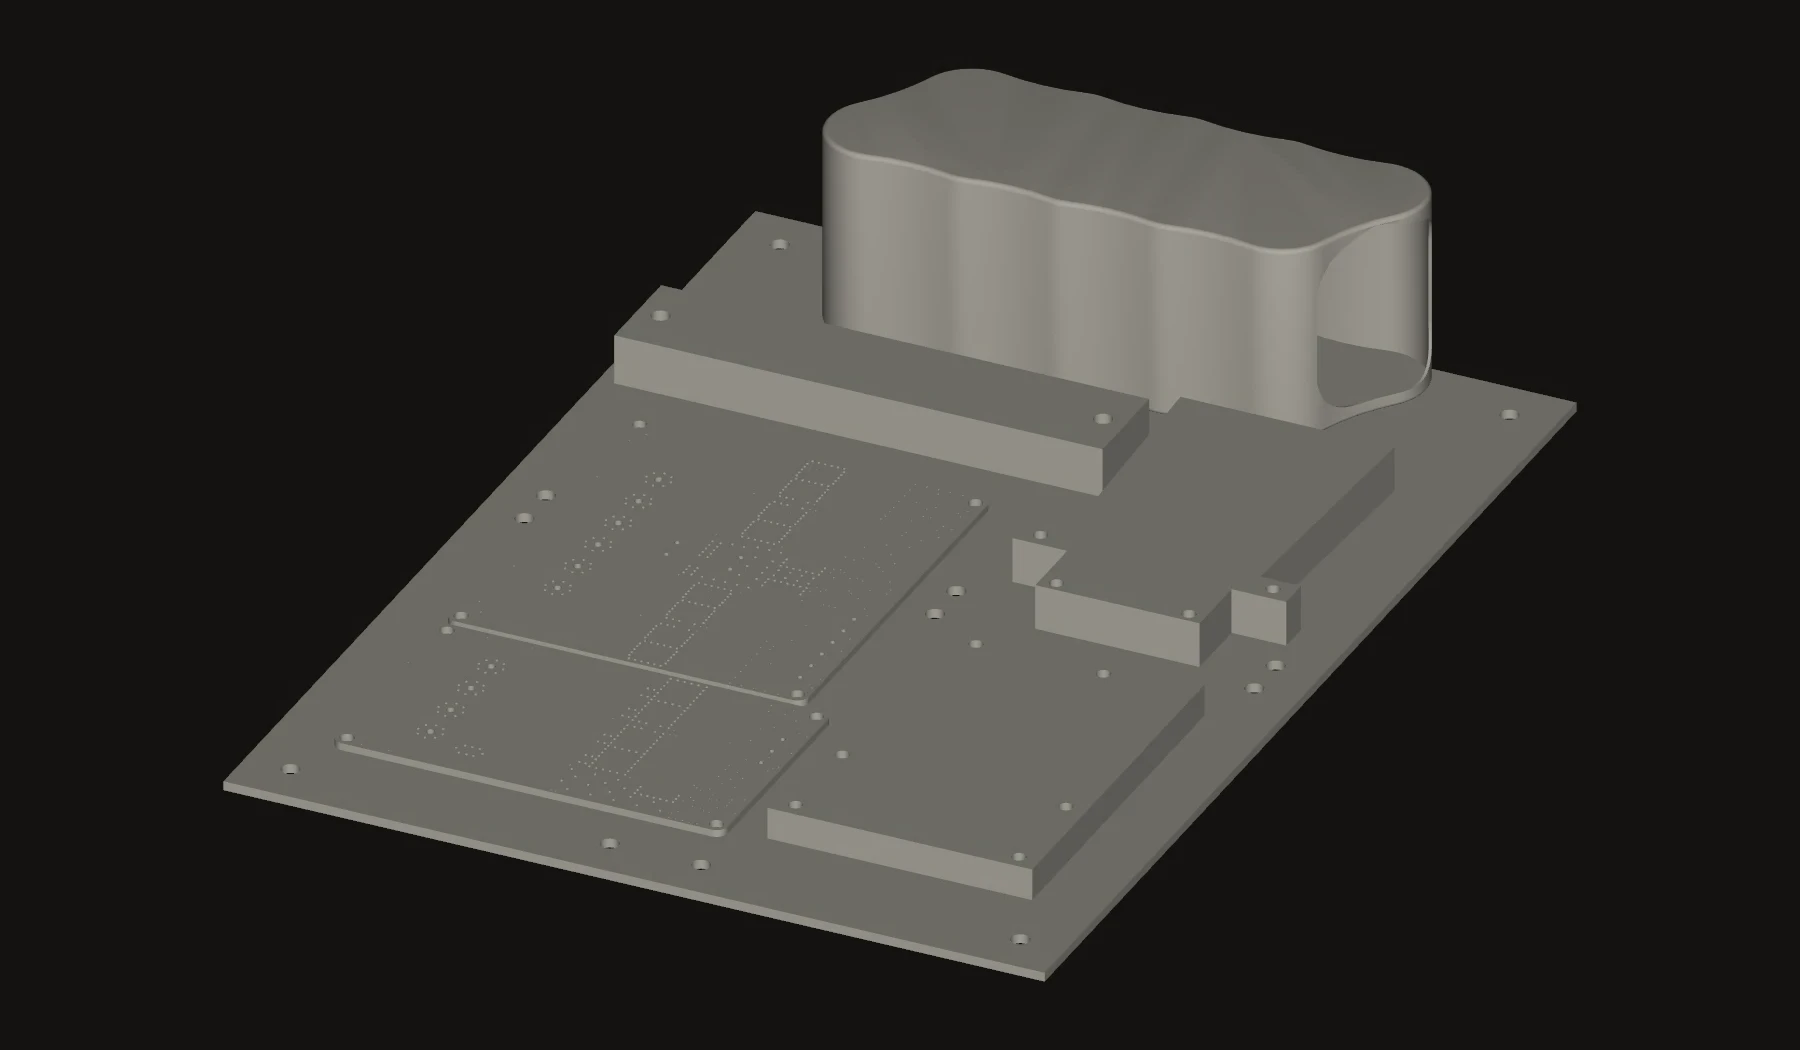
I worked on control software and integration of the PS2 controller receiver. I also handled electronics layout and the electronics mounting plate, contributed manufacturing and fabrication assistance, and helped coordinate the team near the end of the project.
Electronics Mounting / Packaging
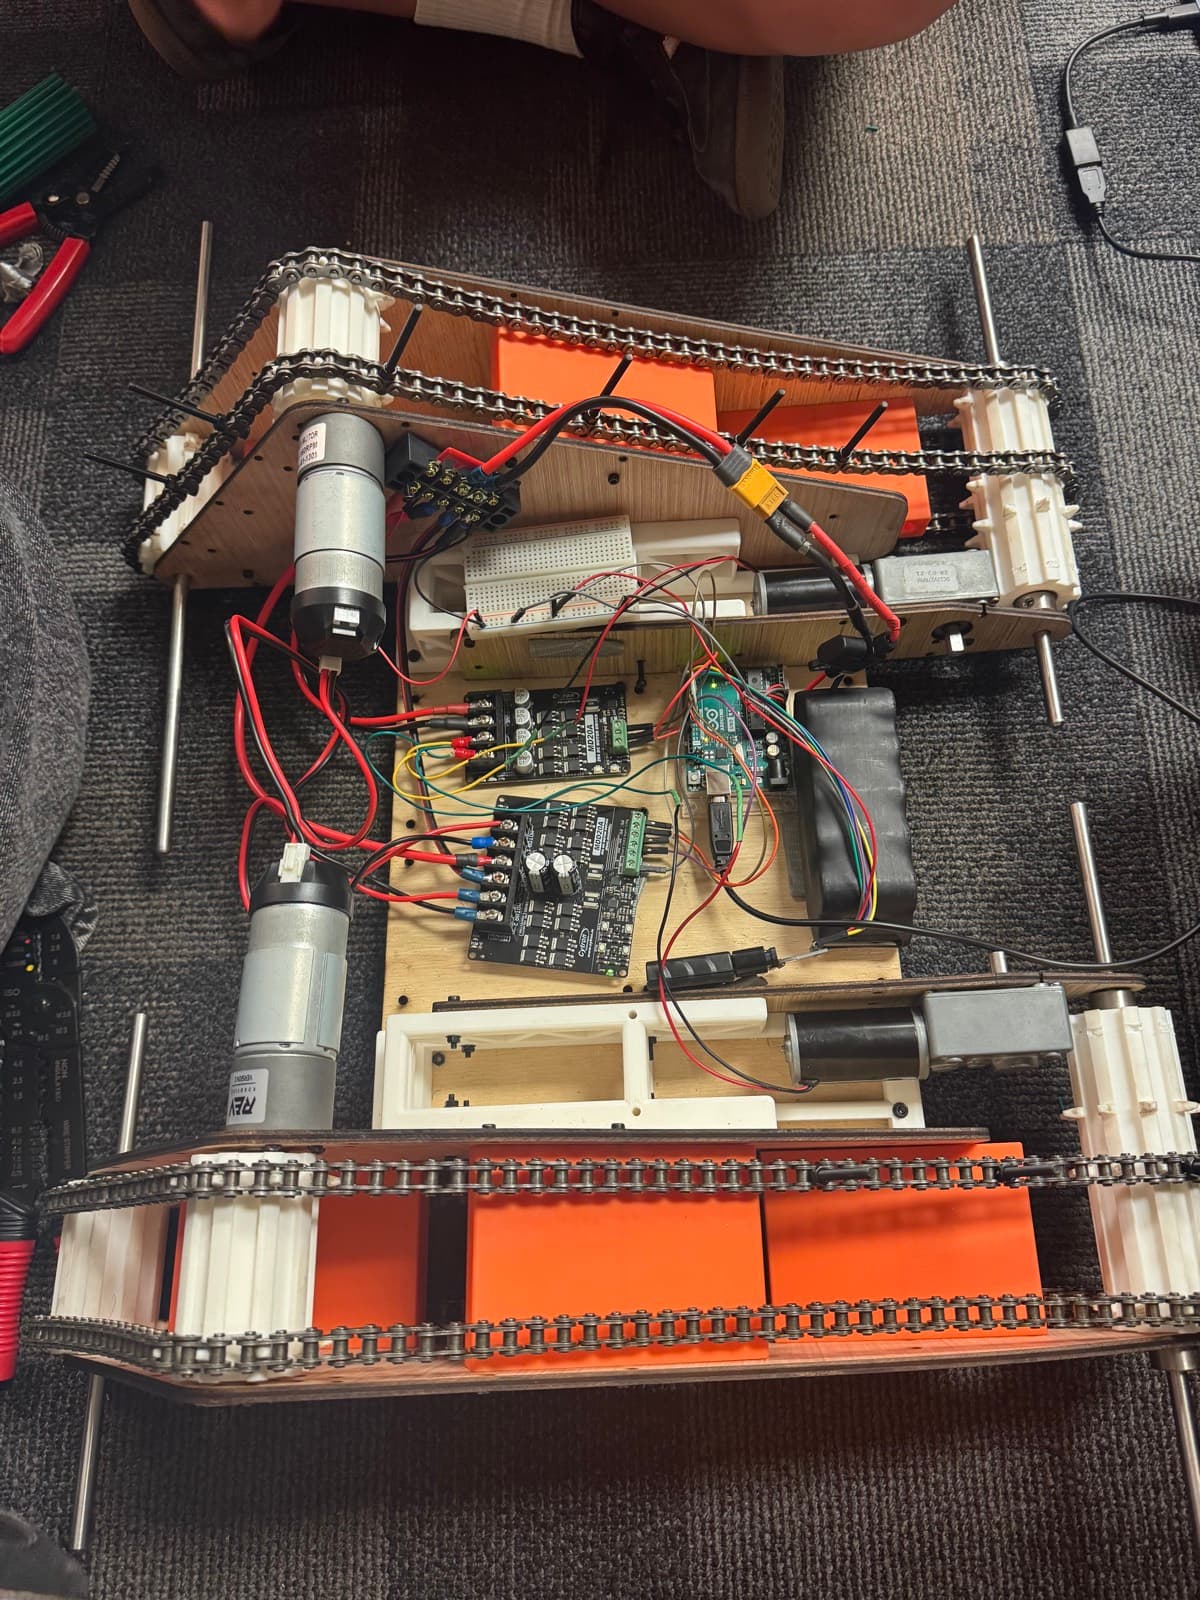
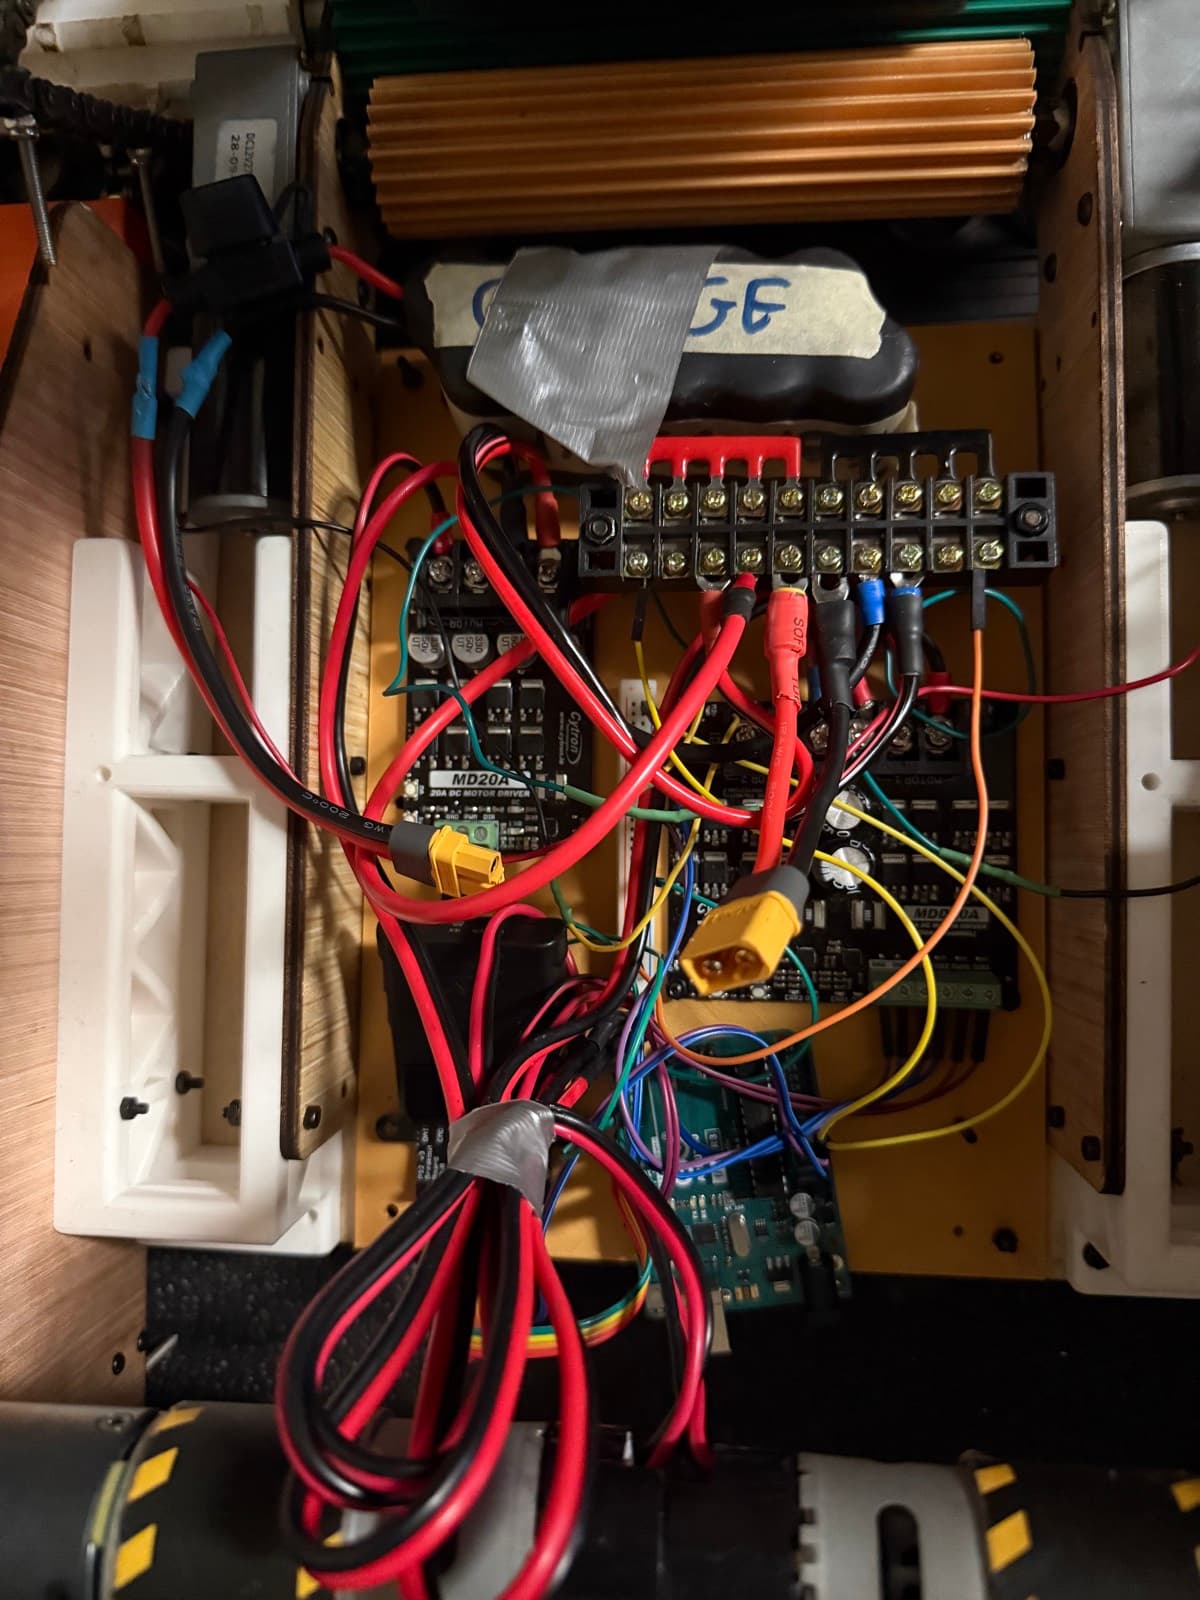
My mechanical contribution centered on the electronics mounting plate and packaging within the team-built robot. The electronics layout brought the controller, motor drivers, power distribution, and wiring together as an integrated assembly.
Most of the mechanical CAD and overall mechanical design were done by teammates, including the chassis, drivetrain, and climbing assemblies. The full assembly shown here provides context for my electronics and integration work.
Build
The photographs show the physical robot, its electronics and wiring, and the team on competition day.